Research
Now
I'm currently drafting my PhD thesis proposal on human intent prediction for autonomous navigation, as part of the Center for Complex Engineering Systems (CCES), a collaboration between MIT and King Abdulaziz City for Science and Technology (KACST) in Saudi Arabia.
Robots that move through spaces shared with people need to anticipate where those people are going, not just react to where they are. My work focuses on the conditions that make this hard in practice: predictions that run in real time on board the robot, environments that change as the robot moves through them, and uncertainty estimates that a planner can use to stay safe.
MIT Mechatronics Research Lab
Research Assistant
- Developing structured multitask Gaussian processes for probabilistic full-body human motion prediction
- Built a test rig pairing a UR5 arm with adjustable cameras for evaluating object detection and manipulation algorithms
- Prepared the evaluation dataset and produced the results section of the demonstration video for our ICRA 2024 paper on how perception affects safety
Writeups
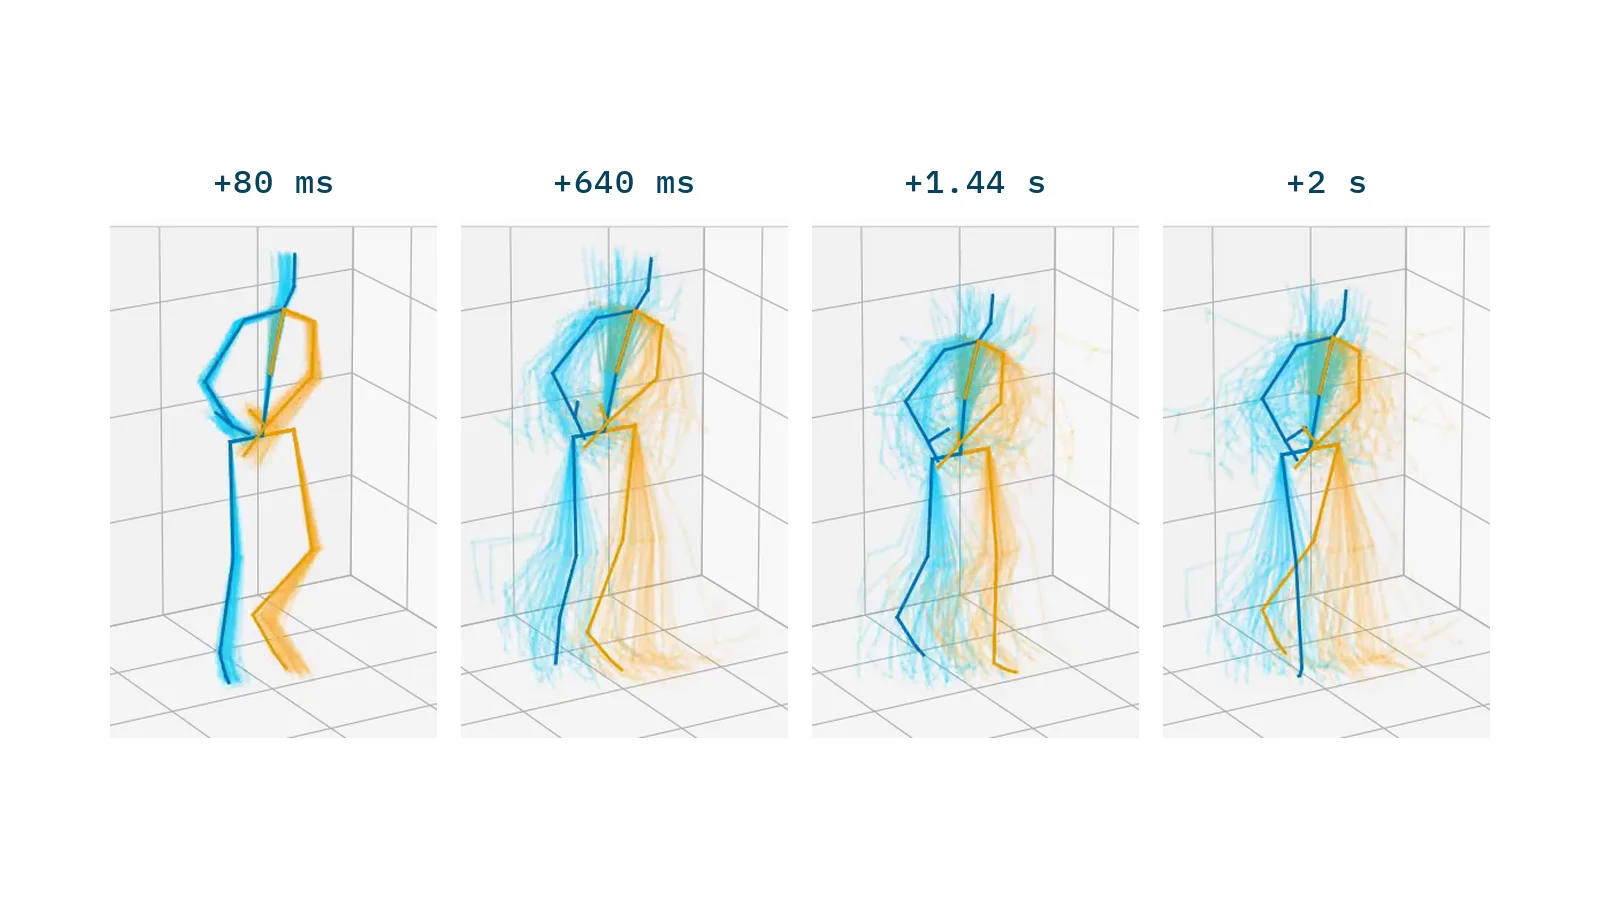
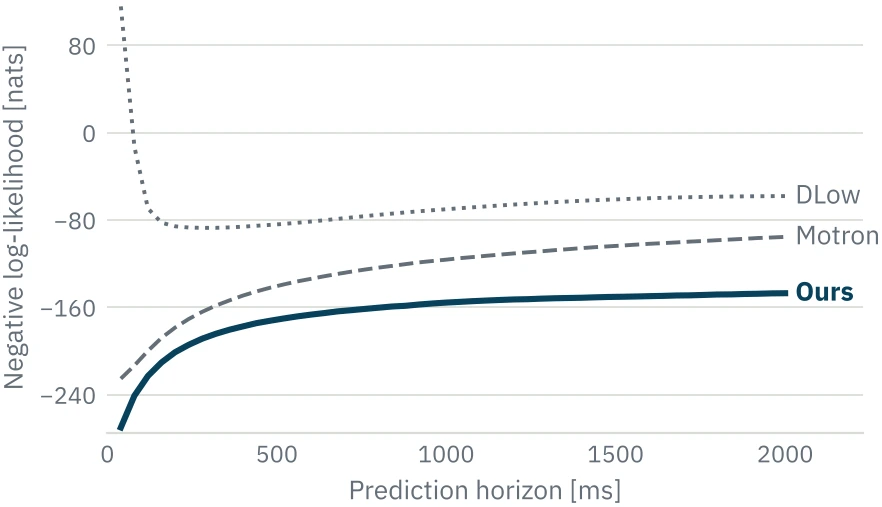
Structured Gaussian Processes for Human Motion Prediction
A compact structured Gaussian process for full-body human motion prediction with closed-form, temporally structured uncertainty.
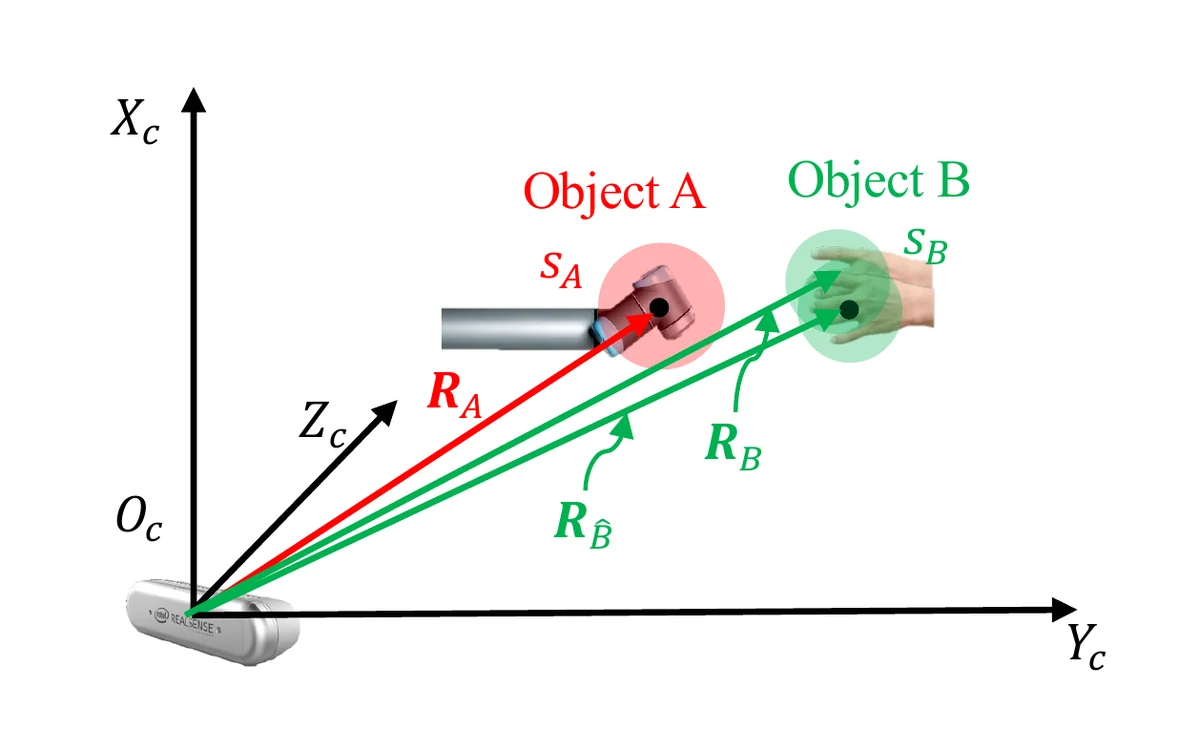
Perception Metrics for Safe Human–Robot Collaboration
Safety metrics that tie a detector's accuracy and speed to collision risk, plus an attentive processing strategy that cuts inference time by up to 30%.
Before
NCTU Computer Games and Intelligence Lab
Research Intern
- Trained a temporal-difference learning agent in C++ to play 2048, reaching the 2048 tile after 2,000 training rounds and a 93% win rate after 20,000
- Investigated how the probability of spawning a 4-tile affects score and learning speed