Projects
Featured
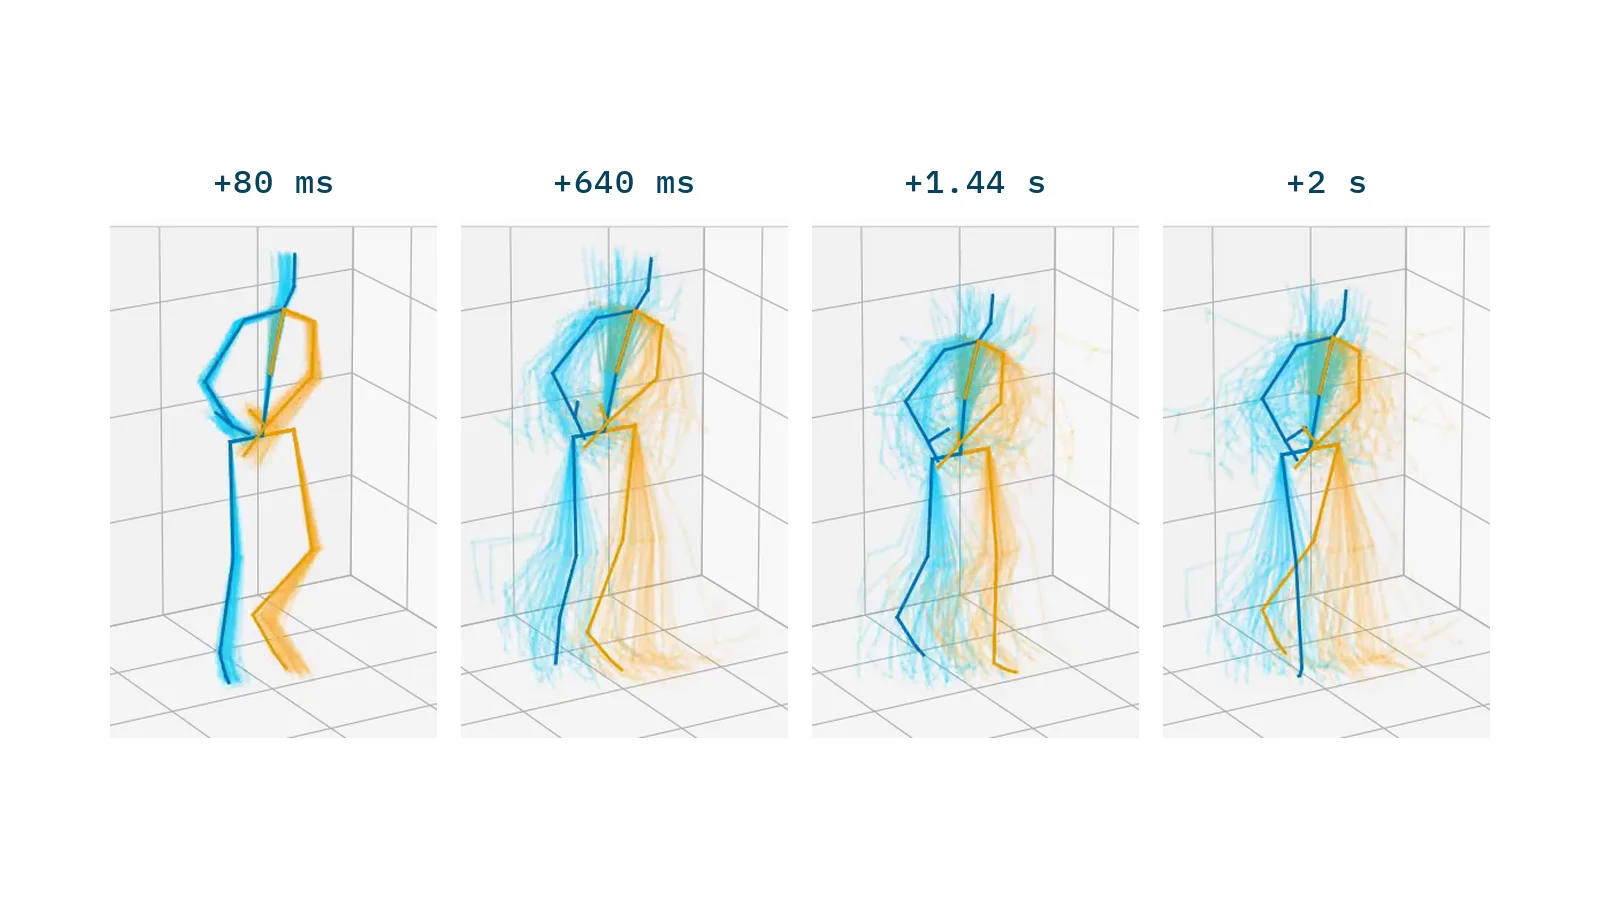
Structured Gaussian Processes for Human Motion Prediction
A compact structured Gaussian process for full-body human motion prediction with closed-form, temporally structured uncertainty.
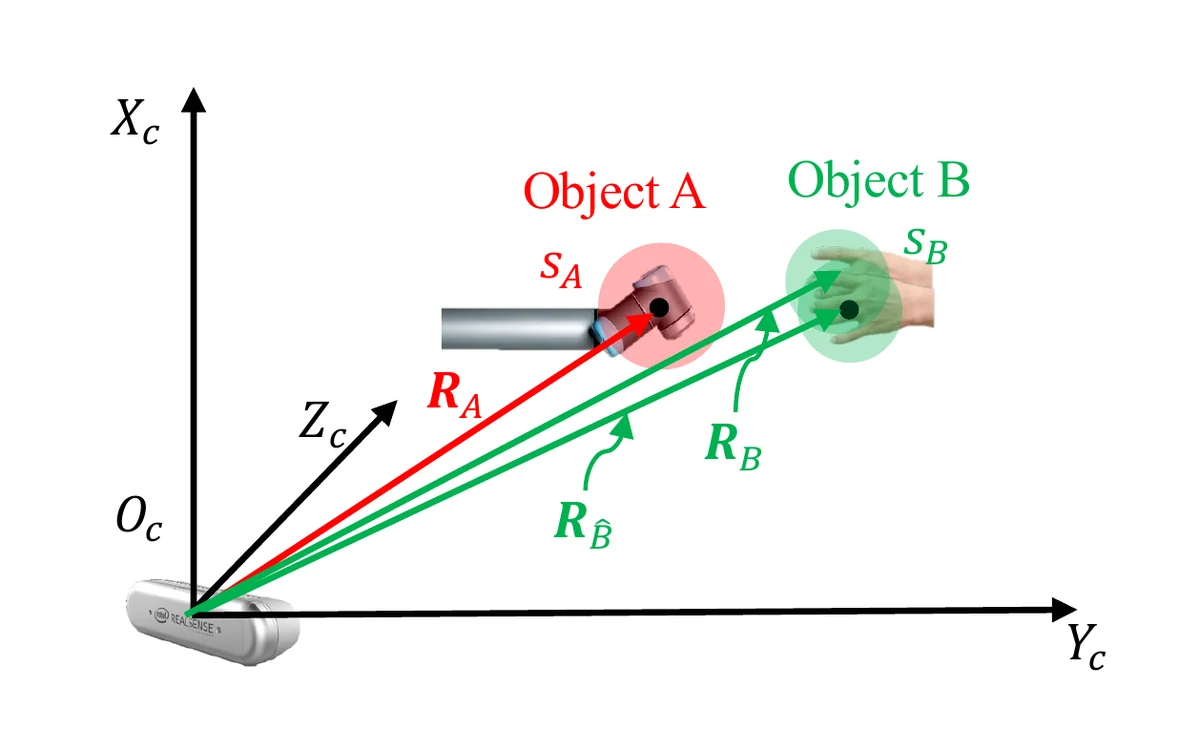
Perception Metrics for Safe Human–Robot Collaboration
Safety metrics that tie a detector's accuracy and speed to collision risk, plus an attentive processing strategy that cuts inference time by up to 30%.
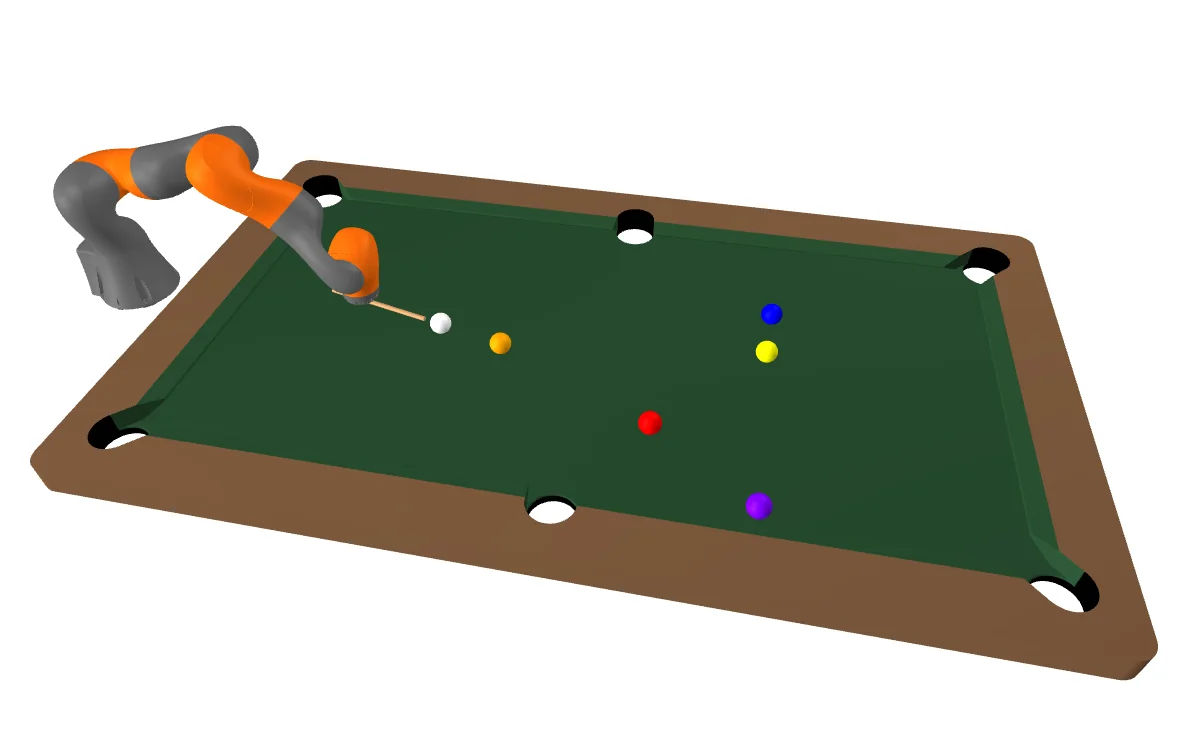
Autonomous Pool-Playing Robot
Shot planning by allowed angular deviation, IK trajectories, and inverse-dynamics control sank the target ball in every randomized trial.

Autonomous Racecar Navigation
Wall following, visual servoing, particle-filter localization, and sampling-based planning on a 1/10-scale autonomous racecar.

ReVise: A Granular-Jamming Vise
A vise with conformable granular-jamming pouches that grips irregular parts without damaging them, demonstrated by clamping a raw egg.
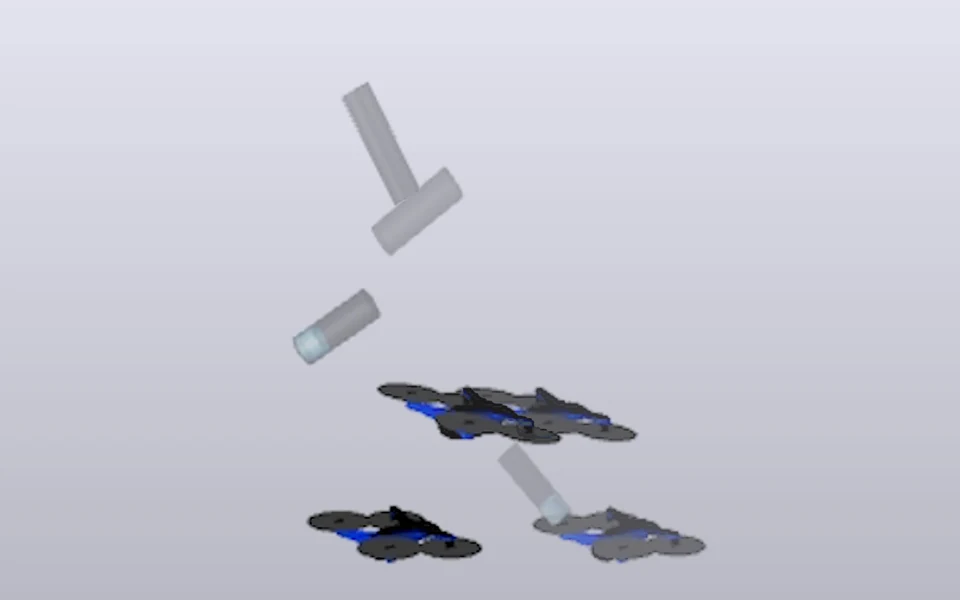
Bottle-Flipping Quadrotor
A hybrid trajectory optimization that throws, spins, and catches a water bottle with a quadrotor in simulation.
More
- Modular Play Instrument for Cognition Research, Early Childhood Cognition Lab
- Arduino Robot Car, 16.632 Intro to Autonomous Machines
- Joystick-Controlled Rubber Band Turret, Freshman engineering seminar
- Sheet-Metal Soccer Robot, Discover Mechanical Engineering pre-orientation