I'm a PhD candidate in Mechanical Engineering at MIT, building probabilistic models that help robots reason about uncertainty in what people will do next, so they can collaborate safely. View my CV →
Publications
-
ICRA · 2027 Under review
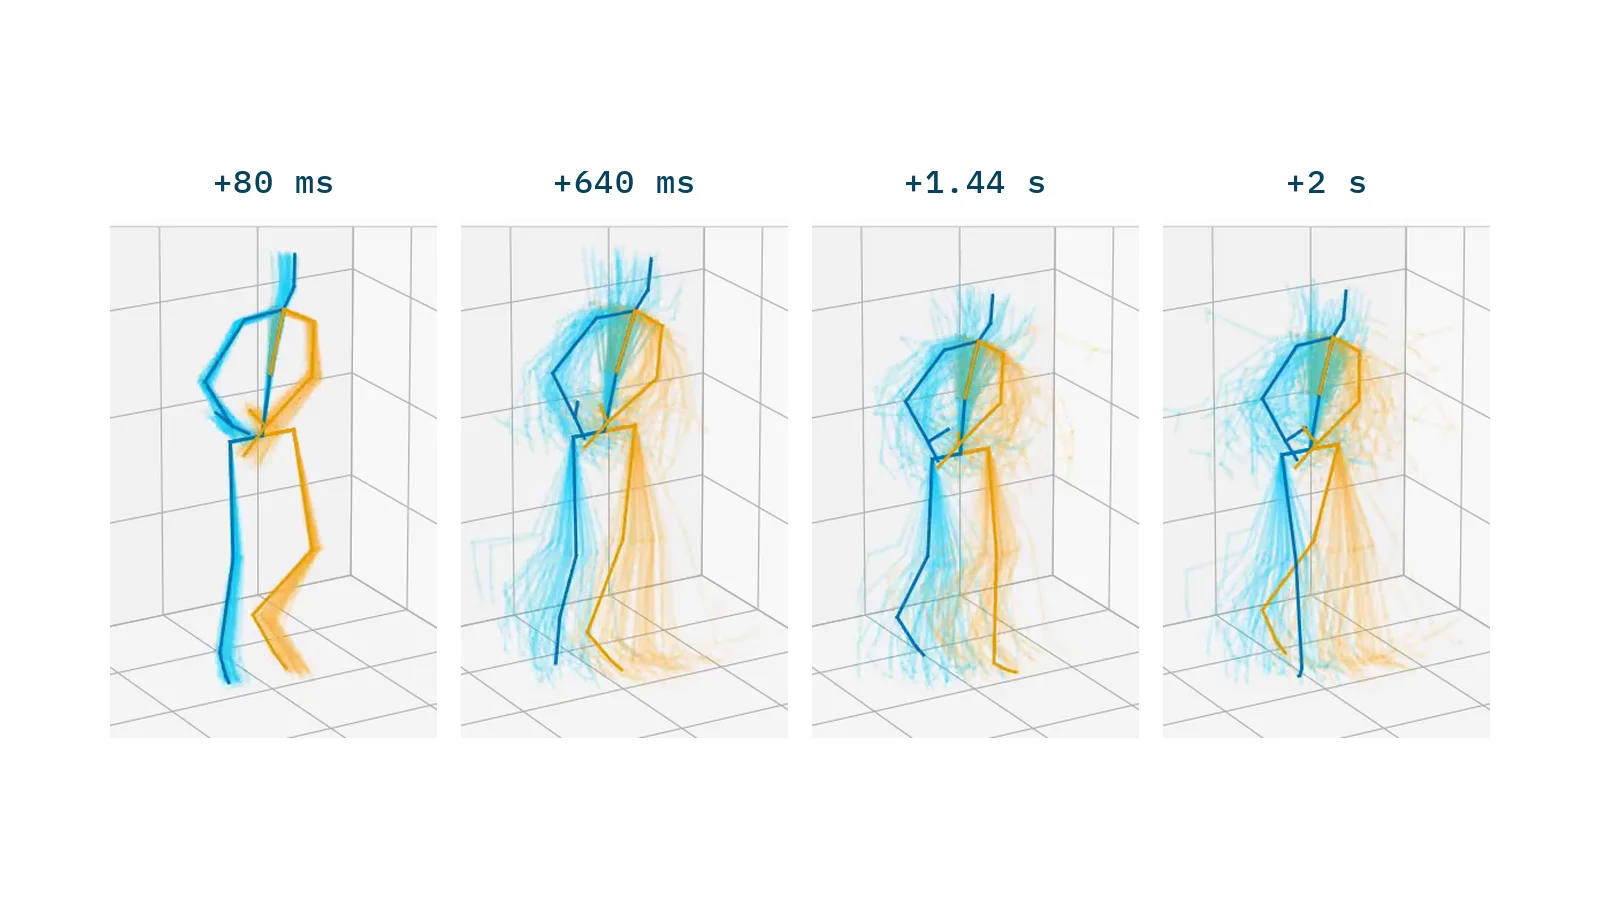
Structured Multitask Gaussian Processes for Probabilistic Full-Body Human Motion Prediction
J. Chong, X. Zhang, K. Youcef-Toumi
-
ICRA · 2024
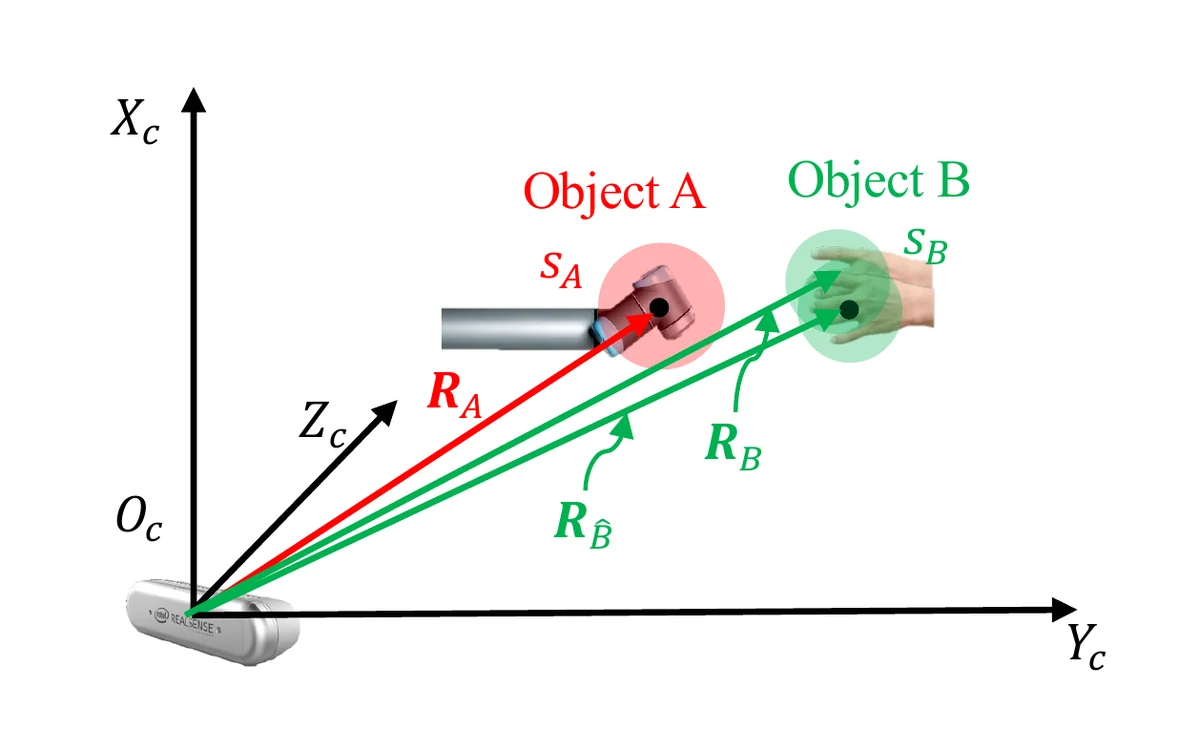
How Does Perception Affect Safety: New Metrics and Strategy
X. Zhang, J. Chong, K. Youcef-Toumi
-
Patent · 2026 Pending
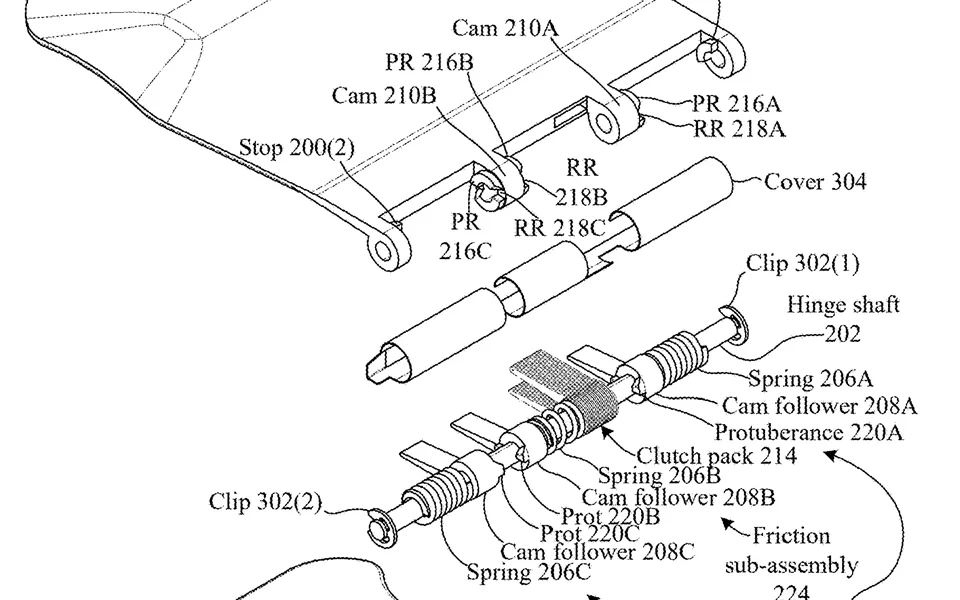
Multi-Function Hinge
J. Chong, D. Yaremenko, B. Tomky, D. Caplow-Munro · US 2026/0143604 A1
ProjectsAll projects →
-
6.4212 Robotic Manipulation · 2023 Outstanding Project
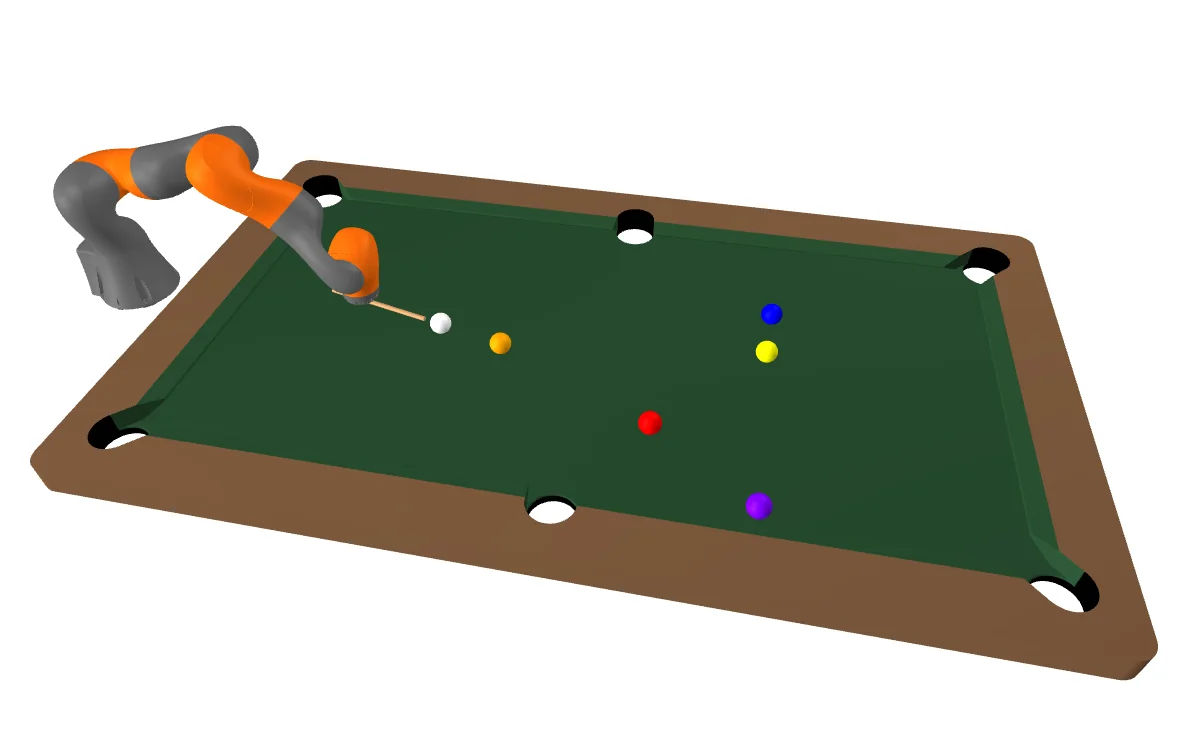
Autonomous Pool-Playing Robot
Shot planning by allowed angular deviation, IK trajectories, and inverse-dynamics control sank the target ball in every randomized trial.
-
6.141 Robotics: Science and Systems · 2022
Autonomous Racecar Navigation
Wall following, visual servoing, particle-filter localization, and sampling-based planning on a 1/10-scale autonomous racecar.
-
6.8210 Underactuated Robotics · 2023
Bottle-Flipping Quadrotor
A hybrid trajectory optimization that throws, spins, and catches a water bottle with a quadrotor in simulation.

ExperienceAll experience →
- Computer Vision Research Intern, GE Vernova Advanced Research Center
- Mechanical Engineering Intern, Microsoft
- Graduate and Undergraduate Engineering Intern, Rotor Technologies